All projects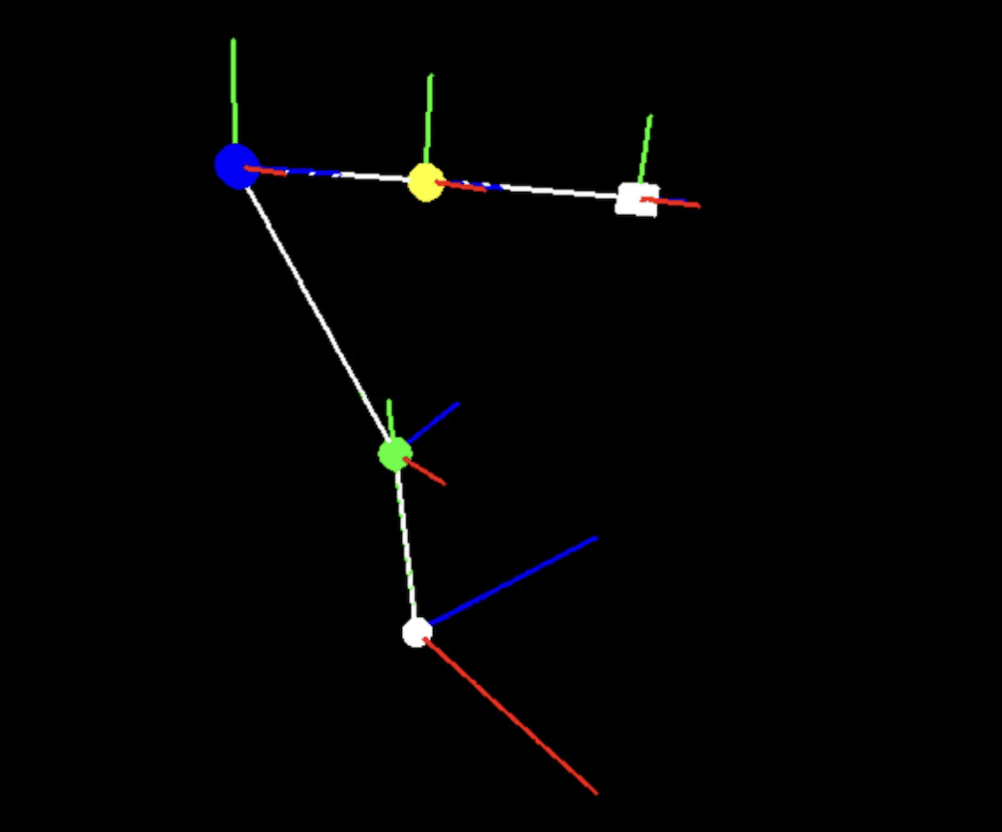
Robot Kinematics Graphics Engine
Python/ATCS coursework
- Built
- 2025-01-01
- Stack
- Python · Pygame
- Context
- ATCS coursework
Overview
A 3D renderer and an inverse kinematics solver, both written from scratch in Python, with nothing but pygame putting pixels on the screen. Every transformation is homogeneous matrix maths I implemented myself, and every pixel is rasterised on the CPU, so no GPU is involved anywhere in it. The renderer exists to give the kinematics somewhere to live: a 4-axis robotic arm you can drive toward a target and watch solve for its own joint angles, following a generated path to get there. I wrote the theory up as a paper afterwards, which is on this site in full.